MIT's Masked IRL Enhances Robot Instruction Interpretation
By Priya Anand
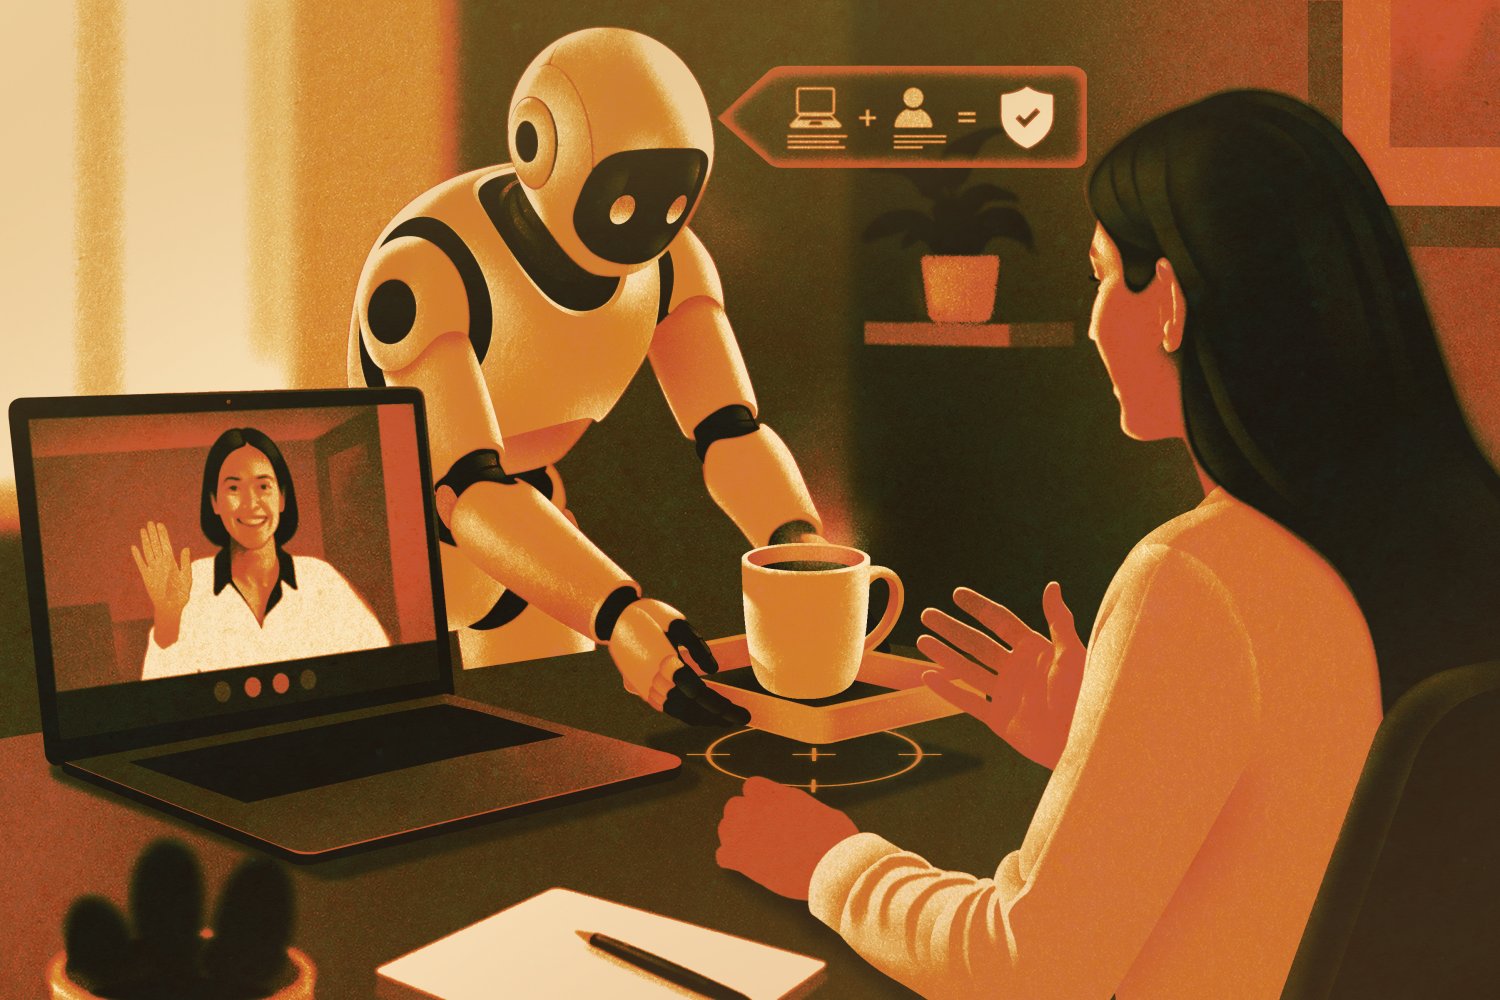
Researchers at MIT have developed a new technique called Masked Inverse Reinforcement Learning (Masked IRL) that utilizes large language models (LLMs) to help robots interpret vague human instructions more effectively. This innovation significantly reduces the need for extensive demonstrations while enhancing precision in robot motion planning.
Masked IRL employs an LLM to elaborate on ambiguous prompts using demonstration data. A second LLM then filters environmental details, identifying them as either 'important' or 'irrelevant' for the robot's planning process. This approach has shown performance gains, with robots identifying unstated user preferences—such as avoiding a laptop during a Zoom call—up to 15% more accurately than standard methods.
The system also demonstrates remarkable data efficiency, requiring nearly five times less demonstration data to train effectively compared to previous methods. This efficiency was evident in both simulated and real-world environments, where robots executed tasks such as moving a coffee mug around a laptop and wiping a table after just 50 kinesthetic demonstrations.
This development aligns with other recent research efforts, such as the LangGrasp framework and studies presented at the 2025 Japanese robotics conference, which leverage LLMs and visual data to interpret ambiguous commands. These advancements collectively represent a trend toward enabling robots to act reliably on underspecified, natural-language human guidance.